AUSPEX in SAR Operations: An Integrated Open-Source Decision-Making Framework for UAVs in Rescue Missions
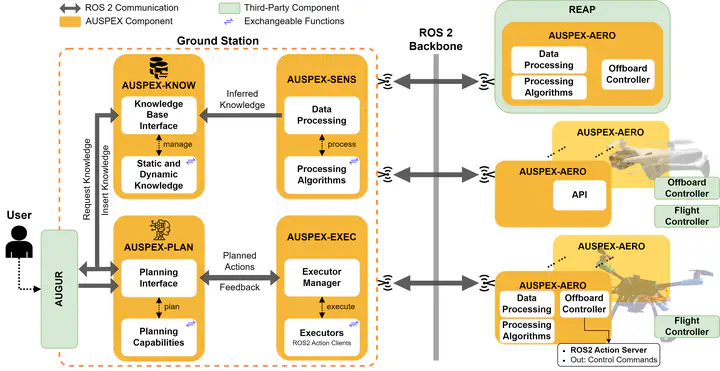 AUSPEX: System Architecture
Abstract
Unmanned Aerial Vehicles (UAVs) have become paramount for Search and Rescue (SAR) missions due to their ability to access hazardous and challenging environments and to rapidly provide cost-effective aerial situational awareness. Nevertheless, current UAV systems are designed for specific tasks, often focusing on benchmarking use cases. Therefore, they offer limited adaptability for the diverse decision-making demands of SAR missions. Furthermore, commercially available integrated UAV systems are non-open-source, preventing further extension with state-of-the-art decision-making algorithms. This paper introduces AUSPEX, a holistic, modular, and open-source framework tailored specifically for enhancing the decision-making capabilities of UAV systems. AUSPEX integrates diverse capabilities for knowledge representation, perception, planning and execution with state-of-the-art decision-making algorithms. Additionally, AUSPEX considers the heterogeneity of available UAV platforms and offers the possibility of including off-the-shelf as well as generic UAVs with an open architecture into the AUSPEX ecosystem. The framework relies only on open-source components to ensure transparency, as well as system scalability and extensibility. We demonstrate AUSPEX’s integration with the Unreal Engine based simulation framework REAP for software-in-the-loop validation and a platform-independent graphical user interface (AUGUR). We demonstrate how AUSPEX can be used for generic scenarios in SAR missions while highlighting its potential for future extensibility.
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.
Kai Sommer
Research Associate
Research associate at the Institute of Flight Systems, focusing on UAV autonomy and knowledge representation for multi-agent systems.