AJCAI 2025 @ Canberra
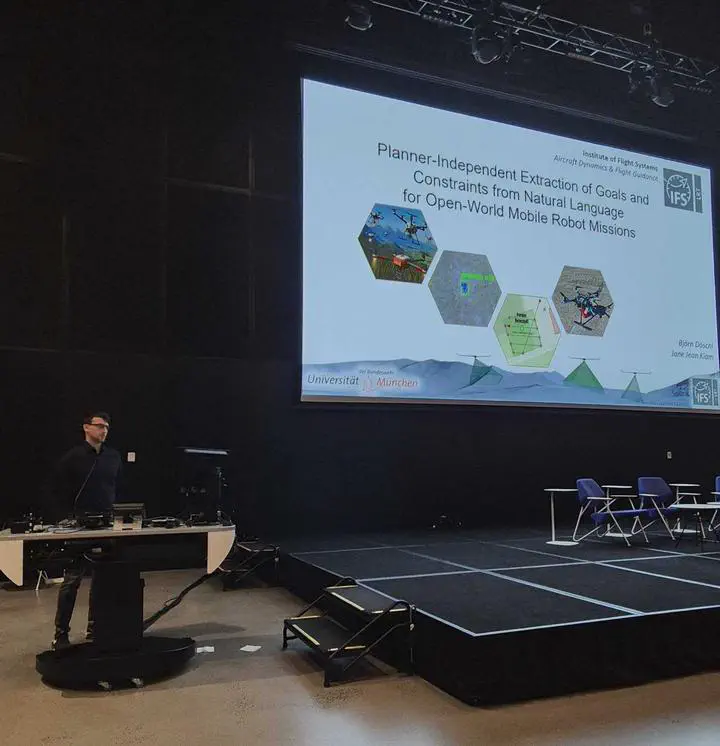
At the 26th Australasian Joint Conference on Artificial Intelligence (AJCAI 2025), held in Canberra, Australia, Björn Döschl presented the paper “Planner-Independent Extraction of Goals and Constraints from Natural Language for Open-World Mobile Robot Missions.” The work introduces a planner-independent pipeline for extracting goals and constraints from natural-language mission instructions and projecting them into planner-specific representations for open-world mobile robot missions.
Conference Details
Conference: AJCAI 2025
Full name: 26th Australasian Joint Conference on Artificial Intelligence
Date: 1–5 December 2025
Presentation date: 4 December 2025
Location: Lowitja O'Donoghue Cultural Centre, Australian National University, Canberra, Australia
Session: Short Oral Session 8: Robotic AI
Summary: Björn Döschl presented research on planner-independent goal and constraint extraction for open-world mobile robot missions.
Paper Details
Title: Planner-Independent Extraction of Goals and Constraints from Natural Language for Open-World Mobile Robot Missions
Authors: Björn Döschl and Jane Jean Kiam
Proceedings: AI 2025: Advances in Artificial Intelligence, Lecture Notes in Computer Science, vol. 16371
Pages: 453–465
DOI: 10.1007/978-981-95-4972-6_35
Springer page: Planner-Independent Extraction of Goals and Constraints from Natural Language for Open-World Mobile Robot Missions
Paper Summary
The paper addresses problem-instance acquisition for robot missions described in natural language. It combines an LLM-based goal and constraint extraction module with a planner-specific projection layer, allowing operator-defined mission instructions to be translated into structured representations for downstream planning systems. The approach is evaluated on mission instructions and demonstrated in AUSPEX for a Search and Rescue UAV scenario.
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.