ICAPS 2025 @ Melbourne
At the 35th International Conference on Automated Planning and Scheduling (ICAPS) 2025, held in Melbourne, Victoria, Australia, members of the AI Lab presented several contributions around UAV planning, simulation, dynamic replanning, and natural-language mission specification.
Max Sommer and Björn Döschl presented the system demonstration “Dynamic REAP: Bringing Life into Simulations for UAV Planning and Acting Frameworks.” Björn Döschl also presented the PlanRob workshop paper “Making Unified Planning Dynamic by Incorporating World State Updates via Feedback Loops” and a poster on “Planner-Independent Extraction of Goals and Constraints from Natural Language for Open-World Mobile Robot Missions.”
Conference Details
Conference: ICAPS 2025
Full name: 35th International Conference on Automated Planning and Scheduling
Date: 9–14 November 2025
Location: Melbourne, Victoria, Australia
Summary: MASC and BJDO presented research contributions on UAV simulation, dynamic planning, and natural-language goal and constraint extraction.
System Demonstration
Title: Dynamic REAP: Bringing Life into Simulations for UAV Planning and Acting Frameworks
Presented by: Max Schnell and Björn Döschl
Authors: Kai Sommer, Björn Döschl, Jane Jean Kiam
Demo page: ICAPS 2025 System Demonstrations
Paper: Download the demo paper
Original PDF: ICAPS demo paper PDF
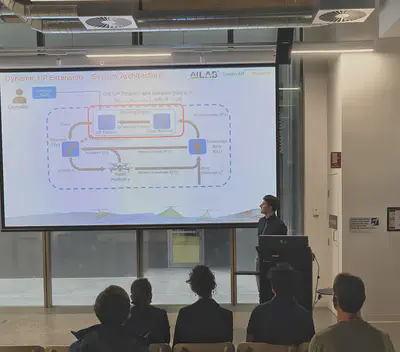
Dynamic REAP extends UAV simulation for planning and acting frameworks by combining accurate vehicle physics with georeferenced semantic segmentation and dynamic background characters. The system demonstration shows how realistic Search and Rescue scenarios can be used to validate UAV decision-making, perception, and planning pipelines before deployment in real-world missions.
PlanRob Workshop Paper
Workshop: PlanRob: Planning and Robotics
Date: 10 November 2025
Title: Making Unified Planning Dynamic by Incorporating World State Updates via Feedback Loops
Presented by: Björn Döschl
Authors: Björn Döschl, Jane Jean Kiam
This workshop paper presents an architectural and functional extension to the Unified Planning framework for dynamic robot missions. The approach constructs planning problem instances from updated world states, integrates execution feedback, and enables replanning during mission execution. The work is demonstrated in the AUSPEX framework with the REAP simulation environment for UAV-based Search and Rescue missions.
Poster Presentation
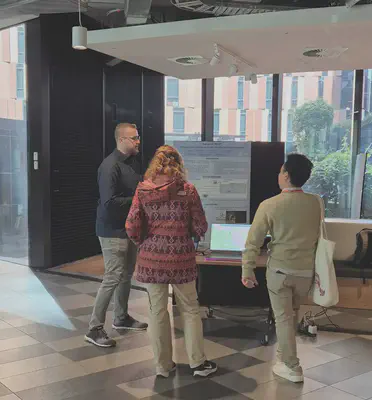
Title: Planner-Independent Extraction of Goals and Constraints from Natural Language for Open-World Mobile Robot Missions
Presented by: Björn Döschl
Authors: Björn Döschl, Jane Jean Kiam
Publication: 38th Australasian Joint Conference on Artificial Intelligence
Project page: Publication page
The poster presents a planner-independent pipeline for extracting goals and constraints from natural-language mission instructions. The approach uses an LLM-based goal and constraint extraction module and a planner-specific projection layer, enabling operator-defined mission goals to be translated into structured representations for downstream planning systems.
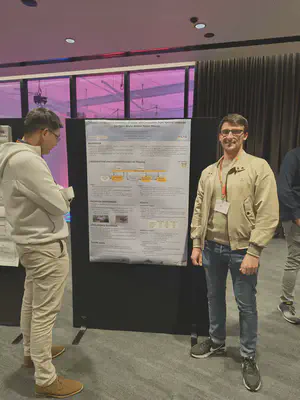
Presented Contributions
- System demonstration: Dynamic REAP for realistic UAV planning and acting simulations.
- Workshop paper: Dynamic UP extension with world-state updates and feedback-loop-based replanning.
- Poster: Planner-independent goal and constraint extraction from natural-language mobile robot mission instructions.
Gallery
Replace the following placeholders with selected photos from the ICAPS presentations, demo session, workshop talk, and poster session.
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.