SaynFly @ IEEE ROMAN 2025
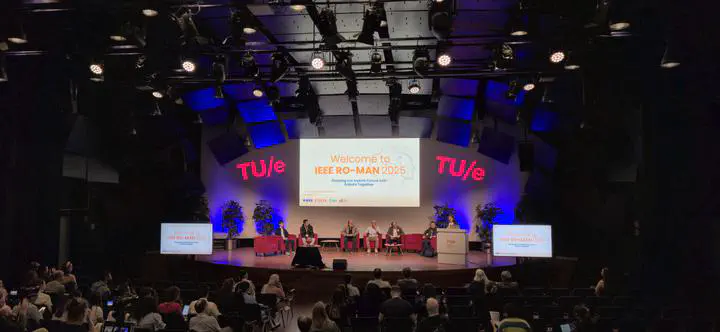
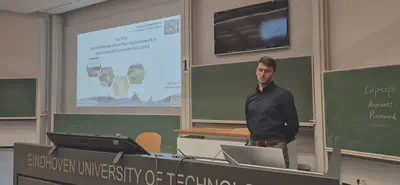
At the IEEE International Conference on Robot and Human Interactive Communication (ROMAN) 2025, held in Eindhoven, Netherlands, Björn Döschl presented his latest research titled “SaynFly: An LLM-Modulo Online Planning Framework to Automate UAV Command and Control.” The conference brought together researchers from robotics, human-robot interaction, and automated systems. SaynFly contributes an LLM-modulo online planning framework for UAV command and control, with a particular focus on search and rescue missions.
Conference Details
Conference: IEEE ROMAN 2025
Date: 25 August 2025
Location: Eindhoven University of Technology, De Zaale, 5612 AZ Eindhoven, Netherlands
Summary: Björn Döschl presented his research on SaynFly at IEEE ROMAN 2025.
Paper Abstract
Command and Control (C2) for Unmanned Aerial Vehicle (UAV) missions requires the dynamic coordination of task planning, environmental perception, and navigation strategies. While Large Language Model (LLM-) modulo planning frameworks have shown promise in addressing such complexity, due to their capabilities to understand natural language and common sense, their limited robustness remains a challenge. Recent adaptions of such frameworks made online planning possible, but they do not scale well with the number of actions. This limits the applicability in robotic frameworks with large sets of parameterized actions, such as those encountered in UAV C2. We introduce SaynFly, an LLM-modulo online planning framework that streamlines the action space by discarding infeasible actions using domain-specific knowledge, while leveraging online heuristic search to mitigate reward uncertainty and automate the C2 processes for UAVs. Test results for our Search and Rescue (SAR) validation scenarios show that SaynFly is 70% more efficient compared to existing frameworks while maintaining or exceeding success rates.
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.