AUSPEX Multi-Drone Success: Heterogeneous Fleet Demonstrates Coordinated Autonomous Operations
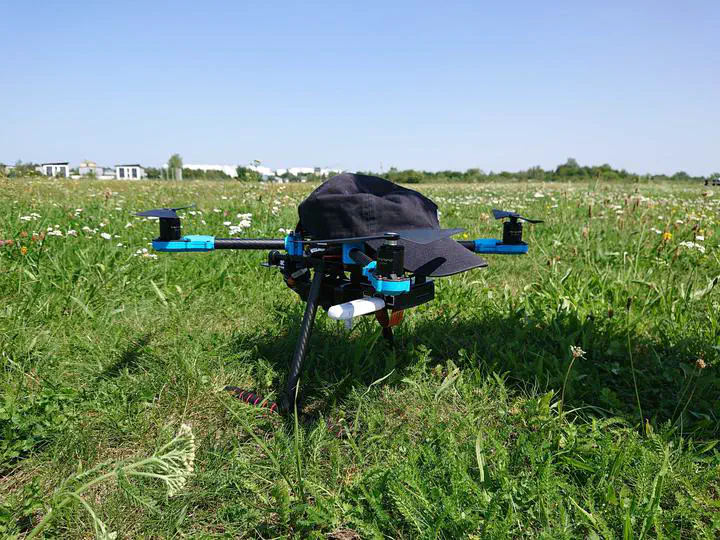
We’re thrilled to announce a major milestone for the AUSPEX framework: successful coordinated flight tests with heterogeneous drones running different autopilot systems. Our Multikopter MK-U20 (ArduPilot) and Holybro x500v2 (PX4) both received and executed mission plans from AUSPEX seamlessly.
English
A breakthrough for the AUSPEX framework ( https://github.com/UniBwM-IFS-AILab/AUSPEX ) - we successfully demonstrated coordinated autonomous operations with a heterogeneous drone fleet, strengthening our real-world search and rescue capabilities.
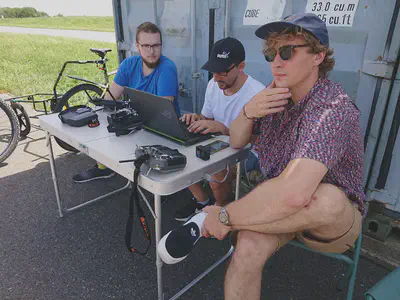
The test involved two different platforms: our Multikopter MK-U20 (ArduPilot) and Holybro x500v2 (PX4). This diversity represents realistic search and rescue scenarios where different organizations deploy various drone types that must work together seamlessly.
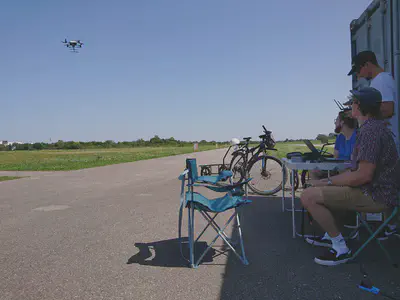
AUSPEX generated mission plans distributed to both drones simultaneously. Each platform received waypoint-based search patterns while maintaining coordination with the overall mission. Both drones executed their tasks autonomously, with remote controls ready only for emergency intervention.
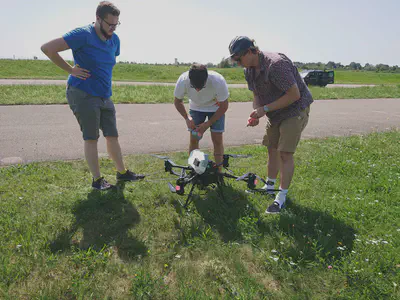
The successful integration across different autopilot ecosystems demonstrates AUSPEX’s platform-agnostic design. The framework effectively communicated with both ArduPilot and PX4 systems, proving its versatility for heterogeneous fleet operations - crucial for real-world scenarios where rescue teams coordinate various drone platforms.
This test validates AUSPEX’s ability to handle multi-platform coordination while maintaining the reliability required for critical missions.
German
Ein Durchbruch für das AUSPEX-Framework ( https://github.com/UniBwM-IFS-AILab/AUSPEX ) - wir demonstrierten erfolgreich koordinierte autonome Operationen mit einer heterogenen Drohnenflotte und stärkten damit unsere Fähigkeiten für reale Such- und Rettungsanwendungen.
Der Test umfasste zwei verschiedene Plattformen: unseren Multikopter MK-U20 (ArduPilot) und eine Holybro x500v2 (PX4). Diese Vielfalt repräsentiert realistische Such- und Rettungsszenarien, bei denen verschiedene Organisationen unterschiedliche Drohnentypen einsetzen müssen, die nahtlos zusammenarbeiten sollen.
AUSPEX generierte Missionspläne, die gleichzeitig an beide Drohnen verteilt wurden. Jede Plattform erhielt wegpunktbasierte Suchmuster bei gleichzeitiger Koordination mit dem Gesamtmissionsziel. Beide Drohnen führten ihre Aufgaben autonom aus, wobei die Fernbedienungen nur für Notfälle bereitgehalten wurden.
Die erfolgreiche Integration verschiedener Autopilot-Ökosysteme demonstriert das plattformunabhängige Design von AUSPEX. Das Framework kommunizierte effektiv mit ArduPilot- und PX4-Systemen und bewies seine Vielseitigkeit für heterogene Flottenoperationen - entscheidend für reale Szenarien, bei denen Rettungsteams verschiedene Drohnenplattformen koordinieren müssen.
Dieser Test validiert die Fähigkeit von AUSPEX, Multi-Plattform-Koordination zu bewältigen und dabei die für kritische Missionen erforderliche Zuverlässigkeit zu gewährleisten.
#UAV #DroneSwarm #AUSPEX #SearchAndRescue #ArduPilot #PX4 #HeterogeneousFleet #AutonomousCoordination
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.