LEAP @ CoRL 2024
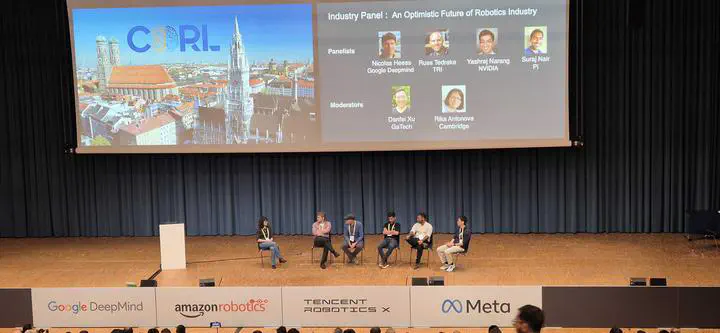
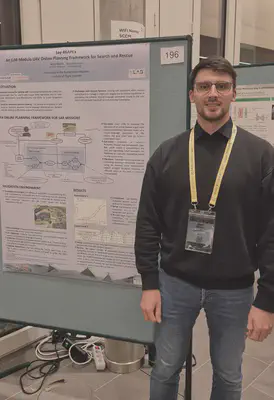
At the LEAP (Learning Effective Abstractions for Planning) workshop, held as part of the Conference on Robot Learning (CoRL) 2024, Björn Döschl presented his latest research titled “Say-REAPEx: An LLM-Modulo UAV Online Planning Framework for Search and Rescue.” The event brought together leading researchers in planning and robot learning, with a focus on abstraction-based methods. The workshop fostered engaging discussions and offered valuable feedback from peers working at the forefront of AI and robotics.
Björn Döschl
Research Associate
Research associate and PhD candidate at the Institute of Flight Systems, focusing on UAV autonomy, swarm intelligence, and multi-agent systems.